Problem-driven opening: why this still matters
Carrier phase tracking delivers the precision we want — but it trips up in real-world conditions: cycle slips, ionospheric delay and multipath wreck the continuity needed for ambiguity resolution. A pragmatic architecture, modelled on a Domain Control Unit idea, helps split responsibilities and stabilise the solution. Practical systems also lean on inertial cues, so integrating an external mems inertial sensor early in the chain is sensible for smoothing and outage bridging.
Why carrier phase tracking stumbles in practice
Carrier phase is fragile because it demands continuous integer-cycle tracking. Multipath and rapid dynamics induce cycle-slips; ionospheric and tropospheric biases skew phase observables; and narrowband receivers struggle with the modern mix of signals. The issue isn’t lack of data — it’s maintaining integrity across frequencies and constellations while keeping timing aligned. Industry primitives here include ambiguity resolution and cycle-slip detection, and both need robust front-end handling.
Domain Control Unit lessons for system structure
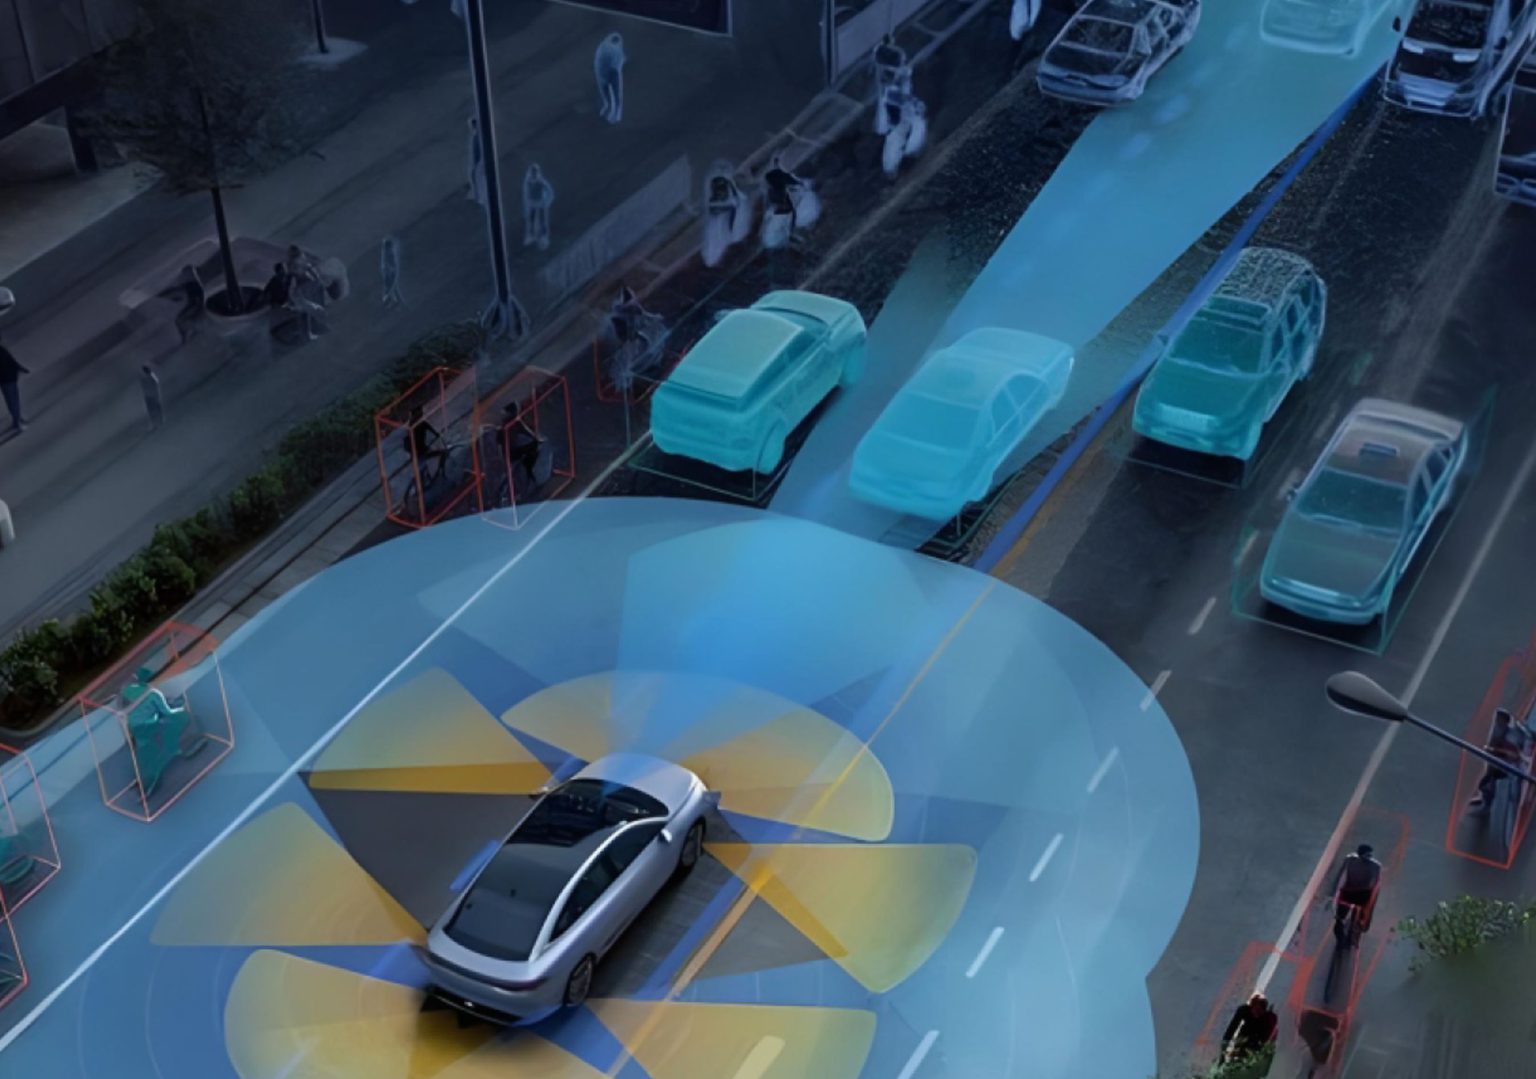
The Domain Control Unit concept works because it separates concerns: signal acquisition/correlation, loop control and higher-level estimation get their own domains, each with clear interfaces. Borrow that structure for carrier-phase tracking: let a specialised RF front-end manage correlators and frequency locks; a mid-layer handle loop filters and cycle-slip mitigation; and a fusion layer resolve ambiguities and output position/attitude. Tight time stamping and disciplined clock steering between domains is critical — treat timing as a first-class signal.
Practical architecture: how to stitch multi‑frequency and multi‑constellation together
Start with a wideband front-end that supports L1, L2/L5 and modern Galileo/BeiDou bands so you get geometric diversity and redundancy. Implement parallel correlators and real‑time cycle‑slip monitors feeding a Kalman-based carrier-phase tracker. Fuse that with a local IMU and an attitude sensor in a tightly coupled estimator to retain fixes through brief outages. Use integer ambiguity resolution only after you’ve validated cycle-slip history and carrier-phase continuity — premature fixing is a common error. Also, keep a watchdog process for ensemble health and clock drift; it prevents subtle degradations from becoming hard-to-debug failures — you’ll thank me later.
Common mistakes and viable alternatives
Teams often rely on a single constellation or a lone frequency and then wonder why availability tanks in urban canyons. Others rush to float-to-fixed ambiguity resolution without robust slip detection. Alternatives worth considering: a loosely coupled GNSS/IMU for low-complexity deployments, or a tightly coupled GNSS/IMU with multi-frequency support for precision RTK/PPP use. PPP‑RTK hybrids offer resilience in sparse network areas, but they demand better orbit and clock modelling. Keep error budgets explicit: multipath, ionosphere, troposphere, and receiver noise — and design to reduce each.
Field evidence and real-world anchor
Operational practice supports these choices: surveyors and autonomous platforms rely on RTK because it routinely delivers centimetre-level positioning in open sky, and adding L5/E5a or extra constellations improves fix availability in challenging environments. That real-world behaviour underlines why structural separation and sensor fusion matter — they directly increase fix continuity and reduce re-initialisation time after disturbances.
Advisory: three golden rules for selecting the right approach
1) Prioritise front-end bandwidth and multi-band support — more frequencies equal faster and more reliable ambiguity resolution. 2) Insist on tight GNSS/IMU coupling for dynamic platforms; the IMU preserves phase continuity during short outages. 3) Build clear domain boundaries with deterministic time stamping and a watchdog for cycle slips and clock steering; failures here cost hours to diagnose.
The payoff is simpler operation and fewer surprise outages — and that’s where a focused engineering partner helps. Archimedes Innovation brings the system-level thinking and integration know-how to turn a Domain Control Unit-inspired design into a field-ready solution. —